#include <Quaternion.h>

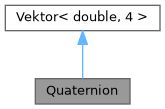
Public Member Functions | |
| Quaternion () | |
| Quaternion (const Quaternion &) | |
| Quaternion (const double &, const double &, const double &, const double &) | |
| Quaternion (const Vector_t &) | |
| Quaternion (const double &, const Vector_t &) | |
| Quaternion (const matrix_t &) | |
| Quaternion | operator* (const double &) const |
| Quaternion | operator* (const Quaternion &) const |
| Quaternion & | operator= (const Quaternion &)=default |
| Quaternion & | operator*= (const Quaternion &) |
| Quaternion | operator/ (const double &) const |
| double | Norm () const |
| double | length () const |
| Quaternion & | normalize () |
| bool | isUnit () const |
| bool | isPure () const |
| bool | isPureUnit () const |
| Quaternion | inverse () const |
| Quaternion | conjugate () const |
| double | real () const |
| Vector_t | imag () const |
| Vector_t | rotate (const Vector_t &) const |
| matrix_t | getRotationMatrix () const |
 Public Member Functions inherited from Vektor< double, 4 > | |
| Vektor () | |
| Vektor (const Vektor< double, D > &rhs) | |
| Vektor (const Vektor< T1, D1 > &rhs) | |
| Vektor (const double &x00) | |
| Vektor (std::initializer_list< double > init) | |
| ~Vektor () | |
| const Vektor< double, D > & | operator= (const Vektor< double, D > &rhs) |
| const Vektor< double, D > & | operator= (const Vektor< T1, D > &rhs) |
| const Vektor< double, D > & | operator= (const double &rhs) |
| Vektor< double, D > & | operator+= (const Vektor< T1, D > &rhs) |
| Vektor< double, D > & | operator+= (const double &rhs) |
| Vektor< double, D > & | operator-= (const Vektor< T1, D > &rhs) |
| Vektor< double, D > & | operator-= (const double &rhs) |
| Vektor< double, D > & | operator*= (const Vektor< T1, D > &rhs) |
| Vektor< double, D > & | operator*= (const double &rhs) |
| Vektor< double, D > & | operator/= (const Vektor< T1, D > &rhs) |
| Vektor< double, D > & | operator/= (const double &rhs) |
| Element_t & | operator[] (unsigned int i) |
| Element_t | operator[] (unsigned int i) const |
| Element_t & | operator() (unsigned int i) |
| Element_t | operator() (unsigned int i) const |
| bool | operator== (const Vektor< double, D > &that) const |
| bool | operator!= (const Vektor< double, D > &that) const |
| Message & | putMessage (Message &m) const |
| Message & | getMessage (Message &m) |
Additional Inherited Members | |
| Public Types inherited from Vektor< double, 4 > | |
| enum | |
| enum | |
| typedef double | Element_t |
Detailed Description
Definition at line 8 of file Quaternion.h.
Constructor & Destructor Documentation
◆ Quaternion() [1/6]
|
inline |
Definition at line 48 of file Quaternion.h.
Referenced by operator*=().
◆ Quaternion() [2/6]
|
inline |
Definition at line 53 of file Quaternion.h.
◆ Quaternion() [3/6]
|
inline |
Definition at line 58 of file Quaternion.h.
◆ Quaternion() [4/6]
|
inline |
Definition at line 63 of file Quaternion.h.
◆ Quaternion() [5/6]
|
inline |
Definition at line 68 of file Quaternion.h.
◆ Quaternion() [6/6]
| Quaternion::Quaternion | ( | const matrix_t & | M | ) |
Definition at line 22 of file Quaternion.cpp.
Member Function Documentation
◆ conjugate()
|
inline |
Definition at line 103 of file Quaternion.h.
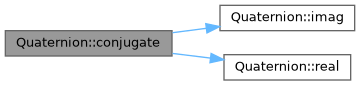
References imag(), and real().
Referenced by OpalBeamline::compute3DLattice(), ParallelTTracker::computeSpaceChargeFields(), Util::getTaitBryantAngles(), inverse(), CoordinateSystemTrafo::invert(), CoordinateSystemTrafo::operator*=(), CoordinateSystemTrafo::print(), H5PartWrapperForPT::readStepHeader(), rotate(), OpalBeamline::save3DInput(), Bend2D::setFieldCalcParam(), and OpalElement::update().
◆ getRotationMatrix()
| matrix_t Quaternion::getRotationMatrix | ( | ) | const |
Definition at line 135 of file Quaternion.cpp.
References normalize().
Referenced by CoordinateSystemTrafo::operator*=().

◆ imag()
|
inline |
Definition at line 117 of file Quaternion.h.
Referenced by conjugate(), operator*(), operator*=(), and operator/().
◆ inverse()
| Quaternion Quaternion::inverse | ( | ) | const |
Definition at line 115 of file Quaternion.cpp.
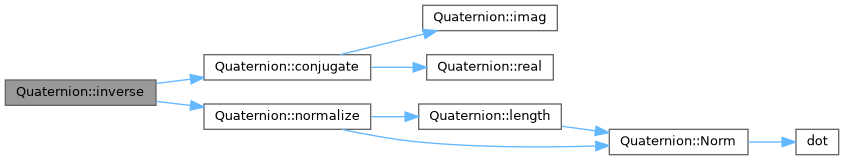
References conjugate(), and normalize().
◆ isPure()
|
inline |
Definition at line 91 of file Quaternion.h.
Referenced by isPureUnit().
◆ isPureUnit()
|
inline |
Definition at line 97 of file Quaternion.h.
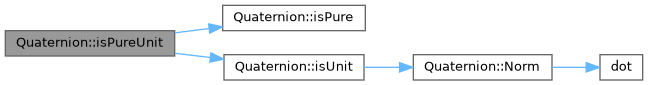
References isPure(), and isUnit().
◆ isUnit()
|
inline |
Definition at line 85 of file Quaternion.h.
References Norm().
Referenced by isPureUnit(), and rotate().

◆ length()
|
inline |
Definition at line 79 of file Quaternion.h.
References Norm().
Referenced by normalize().

◆ Norm()
|
inline |
Definition at line 73 of file Quaternion.h.
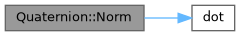
References dot().
Referenced by isUnit(), length(), normalize(), and rotate().
◆ normalize()
| Quaternion & Quaternion::normalize | ( | ) |
Definition at line 102 of file Quaternion.cpp.
References length(), and Norm().
Referenced by getRotationMatrix(), inverse(), and CoordinateSystemTrafo::operator*=().

◆ operator*() [1/2]
| Quaternion Quaternion::operator* | ( | const double & | d | ) | const |
Definition at line 71 of file Quaternion.cpp.
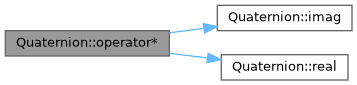
References imag(), and real().
◆ operator*() [2/2]
| Quaternion Quaternion::operator* | ( | const Quaternion & | other | ) | const |
Definition at line 78 of file Quaternion.cpp.
◆ operator*=()
| Quaternion & Quaternion::operator*= | ( | const Quaternion & | other | ) |
Definition at line 84 of file Quaternion.cpp.
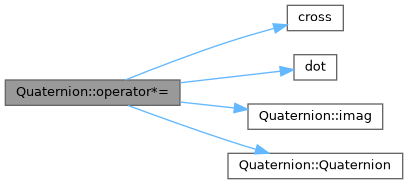
References cross(), dot(), imag(), and Quaternion().
◆ operator/()
| Quaternion Quaternion::operator/ | ( | const double & | d | ) | const |
Definition at line 95 of file Quaternion.cpp.
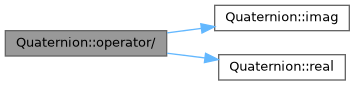
References imag(), and real().
◆ operator=()
|
default |
◆ real()
|
inline |
Definition at line 111 of file Quaternion.h.
Referenced by conjugate(), operator*(), and operator/().
◆ rotate()
Definition at line 122 of file Quaternion.cpp.
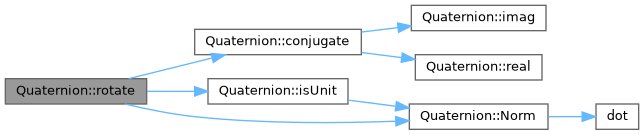
References conjugate(), isUnit(), and Norm().
Referenced by OpalBeamline::compute3DLattice(), Bend2D::getOutline(), Bend2D::getSurfaceMesh(), Util::getTaitBryantAngles(), CoordinateSystemTrafo::invert(), CoordinateSystemTrafo::operator*=(), CoordinateSystemTrafo::print(), and H5PartWrapperForPT::readStepHeader().
The documentation for this class was generated from the following files:
- src/Classic/Algorithms/Quaternion.h
- src/Classic/Algorithms/Quaternion.cpp
